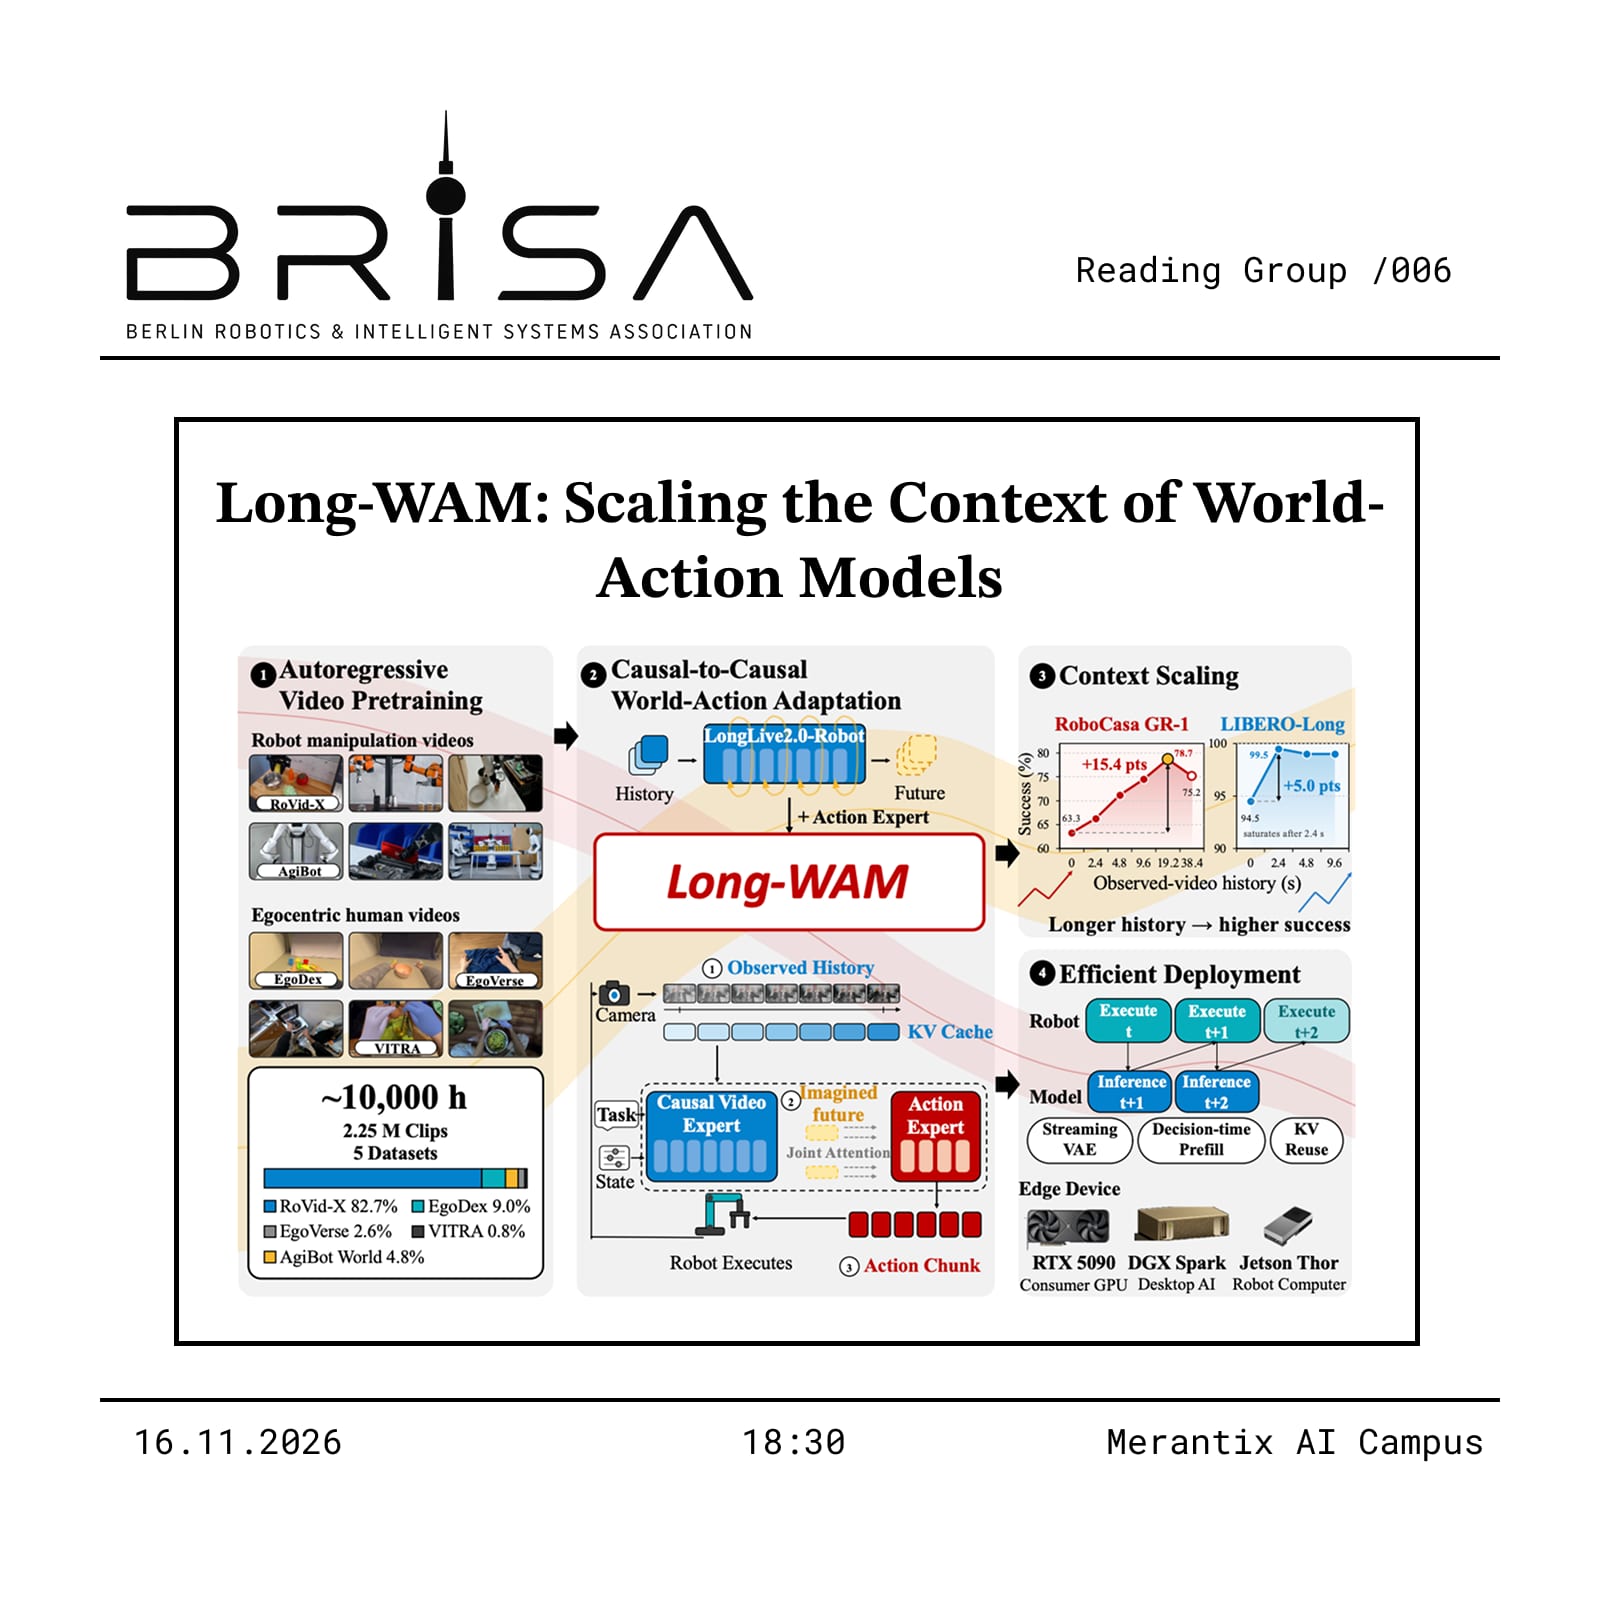
BRISA Reading Group 06 - Long-WAM: Scaling the Context of World-Action Models
This week we look at Long-WAM: Scaling the Context of World-Action Models (Huang et al., 2026) from NVIDIA, MIT, HKU and UCSD, with code and model checkpoints released openly. A robot that only sees the current frame can’t tell whether the cup in front of it is moving, or how far along the task it already is. More visual history sounds like the obvious fix, but history costs time and a robot that
EventAI / MLRobotics